


Robotics
Full-chain coverage of sensory labels, smart hardware, self-study systems, one-stop customization network digital solutions
_Other Organiser
Strong, safe and stable products and services
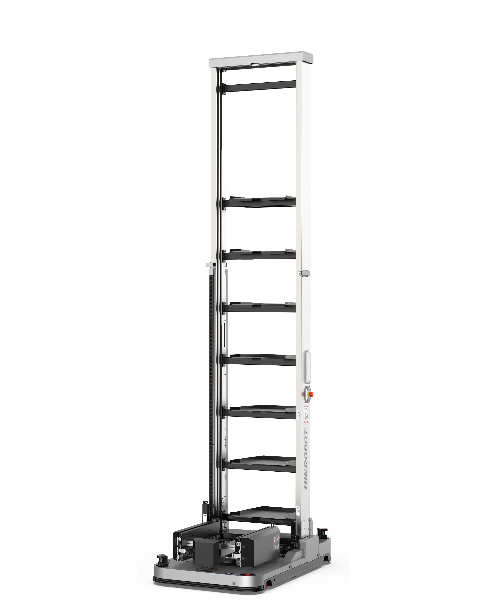
HIKROBOT TP5-50DCH Tote-Handling Robot
TP5-50DCH
- Rating load (kg)
- 300
- Number of silos (number)
- 7
- Channel width (mm)
- 1100
- Type of implementing agency
- Single-deep hug.
- Position accuracy (mm, °)
- ±10,±1
- Consort height (mm)
- 300-4000
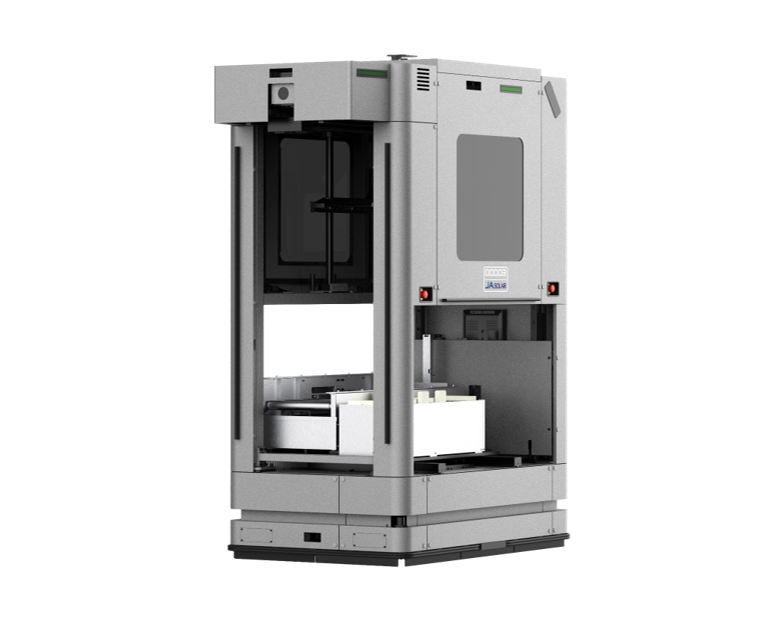
HIKROBOT CHG-300L Load Transfer Mobile Robot
CHG-300L
- Rating load (kg)
- 300
- Rating speed (m/s)
- 1.0
- Navigation Method
- VSLAM / QR code
- Rated acceleration (m/s²)
- 0.3
- Rotation diameter (mm)
- 2310
- The way to hide.
- Laser + Double-eye
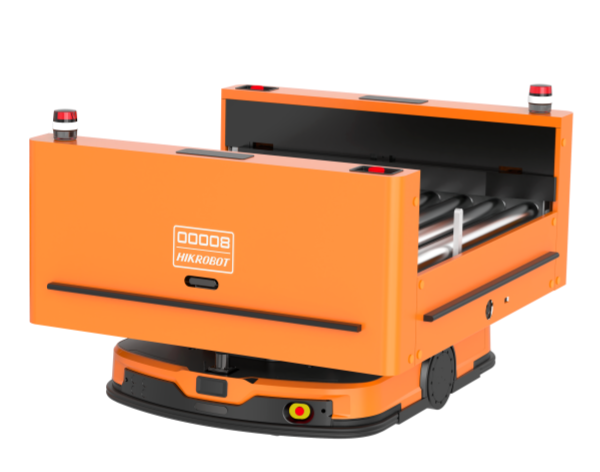
HIKROBOT Q7-CU1-100 Load Transfer Mobile Robot
Q7-CU1-100
- Rating load (kg)
- 100
- Rating speed (m/s)
- 1.0
- Navigation Method
- LSLAM / VSLAM / QR code
- Rated acceleration (m/s²)
- 0.4
- Rotation diameter (mm)
- 1619
- The way to hide.
- Laser + Double-eye
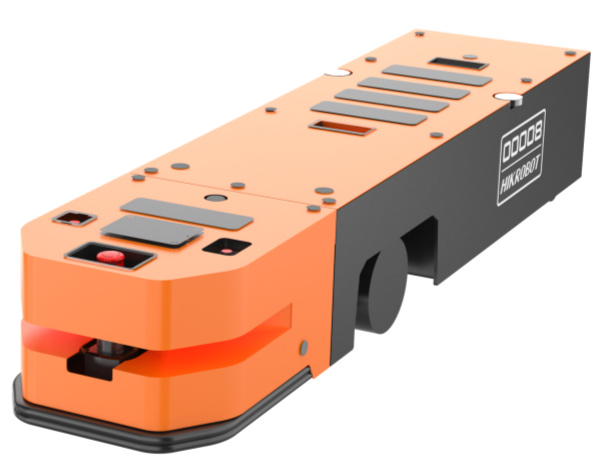
HIKROBOT CT5-500L Load Transfer Mobile Robot
CT5-500L
- Rating load (kg)
- 500
- Rating speed (m/s)
- 1.0
- Navigation Method
- LSLAM / VSLAM / QR code
- Rated acceleration (m/s²)
- 0.5
- Turn radius (mm)
- 1000
- The way to hide.
- Laser
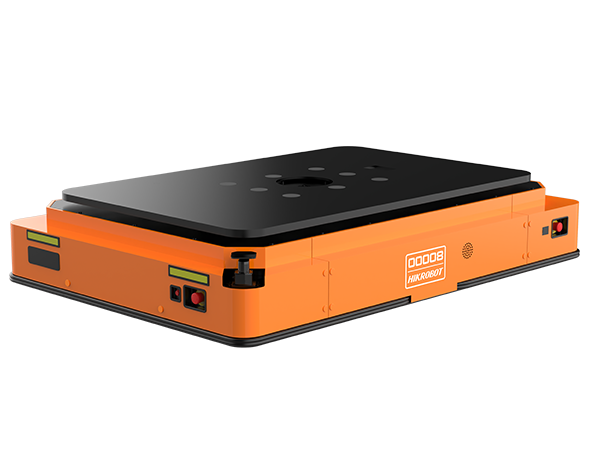
HIKROBOT HL9-3000B Heavy-Duty Mobile Robot
HL9-3000B
- Rating load (kg)
- 3000
- Rating speed (m/s)
- 1.2
- Navigation Method
- QR code / LSLAM / VSLAM
- Rated acceleration (m/s²)
- 0.5
- Drive Type
- Full-Drive
- The way to hide.
- Laser
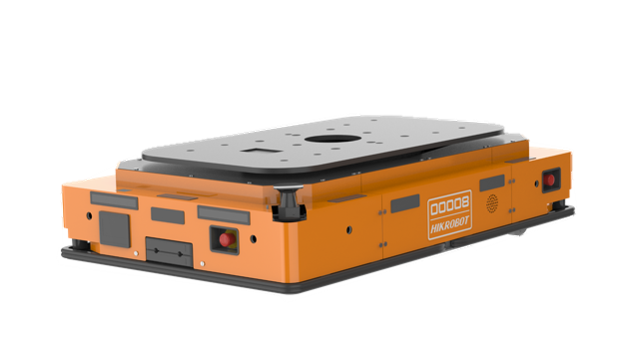
HIKROBOT HL7-1500B Heavy-Duty Mobile Robot
HL7-1500B
- Rating load (kg)
- 1500
- Rating speed (m/s)
- 1.5
- Navigation Method
- QR code / VSLAM / LSLAM
- Rated acceleration (m/s²)
- 0.5
- Drive Type
- Full-Drive
- The way to hide.
- Laser
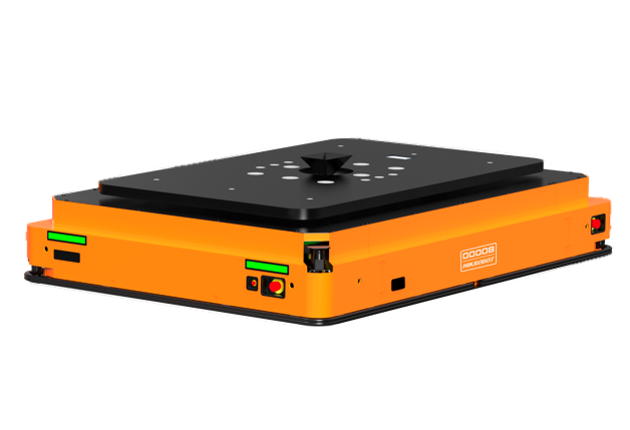
HIKROBOT HL10-6000B Heavy-Duty Mobile Robot
HL10-6000B
- Rating load (kg)
- 6000
- Rating speed (m/s)
- 1.2
- Navigation Method
- QR code / VSLAM / LSLAM
- Rated acceleration (m/s²)
- 0.5
- Drive Type
- Full-Drive
- The way to hide.
- Laser
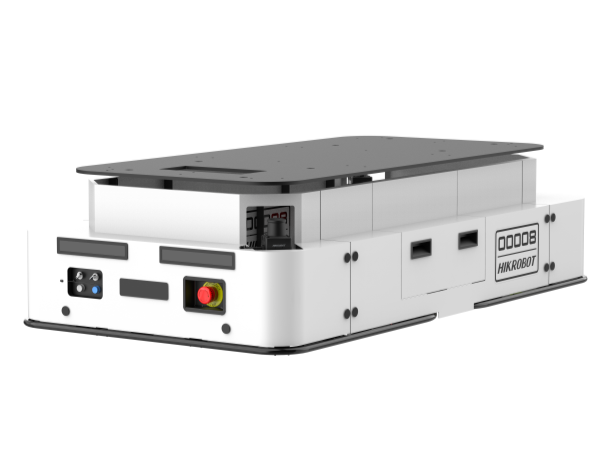
HIKROBOT QC7B-600LO Mobile Manipulator
QC7B-600LO
- Rating load (kg)
- 600
- Rotation diameter (mm)
- 1650
- Navigation Method
- QR Code / LSLAM
- Load face size L*W(mm)
- 1320*630
- Cleanness
- ISO CLASS5 (optional)
- Position accuracy (mm, °)
- ±10,±1
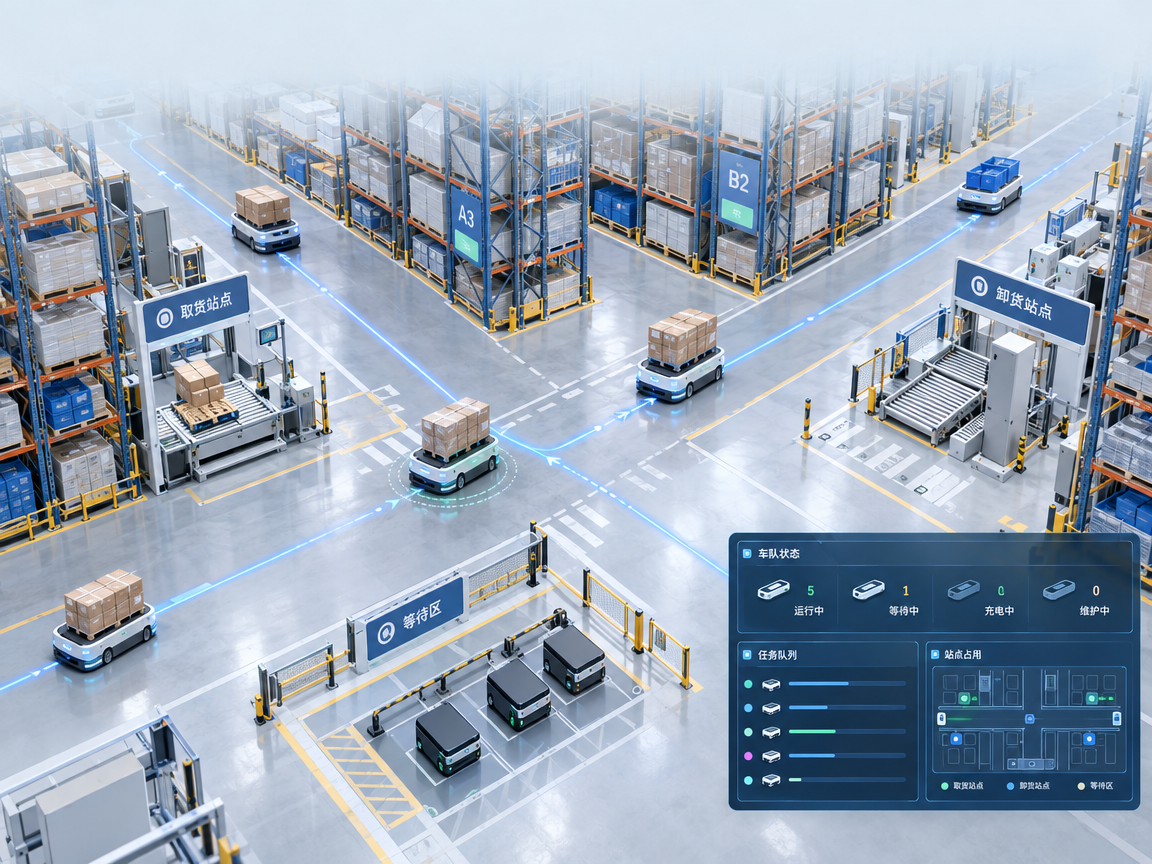
AGV Fleet Management System (Reference Design)
Reference programme
- Source of mandate
- Manual creation, site calls, business interface, by project configuration
- Manage Object
- AGV vehicles, missions, stations, pass areas
- Operational interface
- WMS, MES or other supersystems, interface to be confirmed
- Run Policy
- Priority, vehicle suitability, traffic rules, charging strategy
- Deployment pattern
- Local server or project specified environment
- Acceptance Criteria
- Mission closed loop, sector occupancy, failure recovery and log tracking
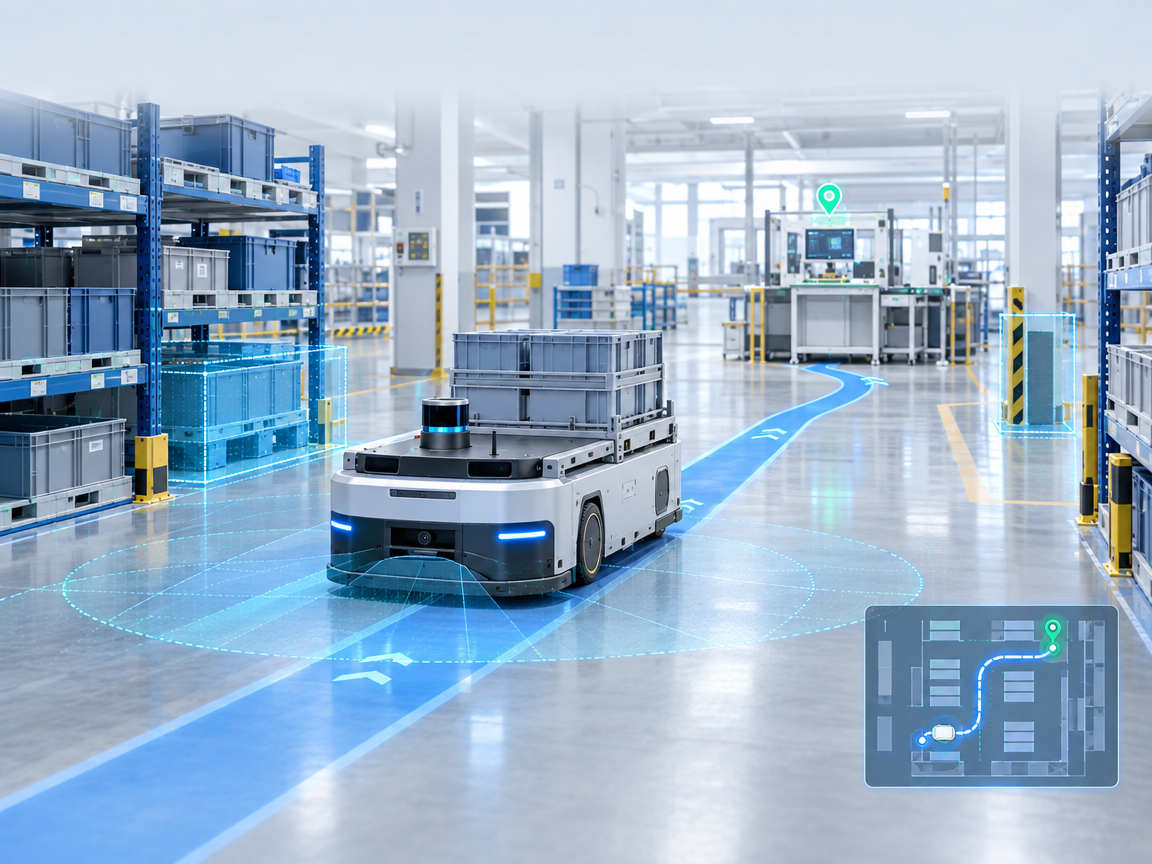
AGV Navigation System (Reference Design)
Reference programme
- Map Object
- Channels, sites, restricted areas, direction and speed areas
- Navigation Method
- Laser, vision, QR code, or hybrid navigation, depending on the vehicle model
- Information access
- Vehicle coordinates, positioning status, navigational results
- Dock Management
- Site location, docking conditions, station verification
- Change management
- Map version, routing and retrometry records
- Acceptance Criteria
- Accessibility, station stability, repositioning and recovery of anomalies
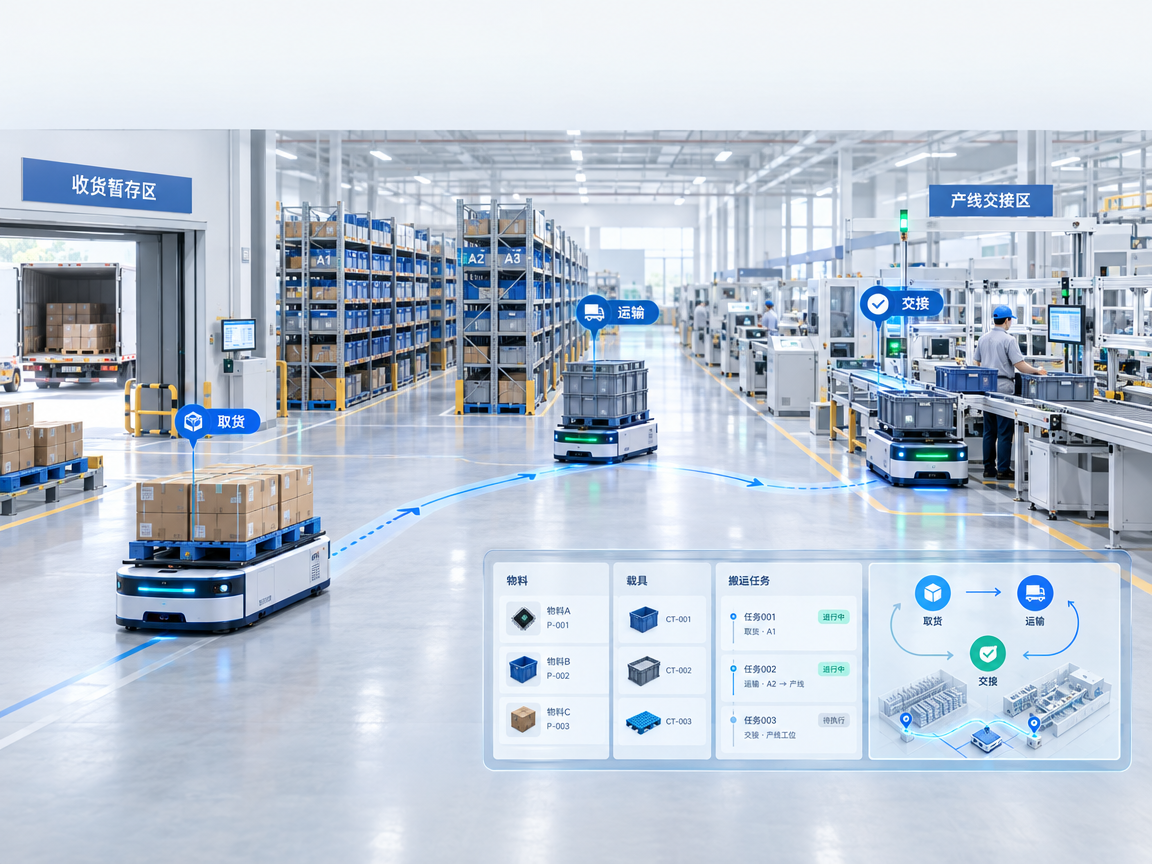
AGV Logistics System Integration (Reference Design)
Reference programme
- Business processes
- Into, out, patches, back-up, etc., configured according to needs
- Object Management
- Materials, trays, boxes, sites and missions
- Business interface
- WMS, MES, dispatch platform, protocol confirmed.
- Means of identification
- Scanning, RFID or manual confirmation, selected by field
- Business records
- Time-consuming, unusual, waiting to cross over.
- Acceptance Criteria
- Material connection, mission callback, site lock-in to the books.
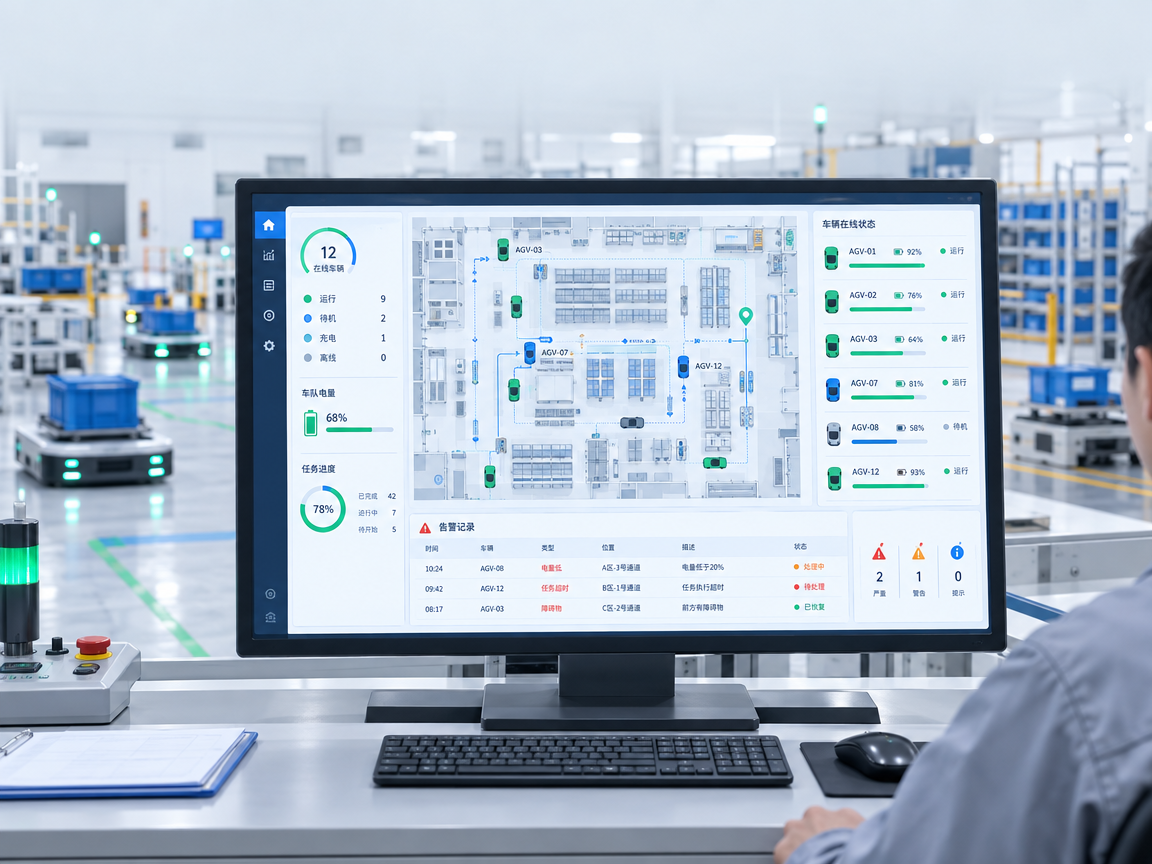
AGV Supervisory Control System (Reference Design)
Reference programme
- Show objects
- Vehicle fleet, missions, maps, sites and alerts
- Operating Permissions
- Management, operation, maintenance etc. by organization
- Data sources
- Vehicle, movement control platform and field equipment interface
- History
- Warning, mission, operation and configuration changes
- Terminal form
- PC or project-specific touch terminals
- Acceptance Criteria
- Permission control, consistency of status, abnormal location and record queries
No content at this time
 Ms. Lei
 Mr. Pang