


AGV Navigation System (Reference Design)
Model: Reference Design
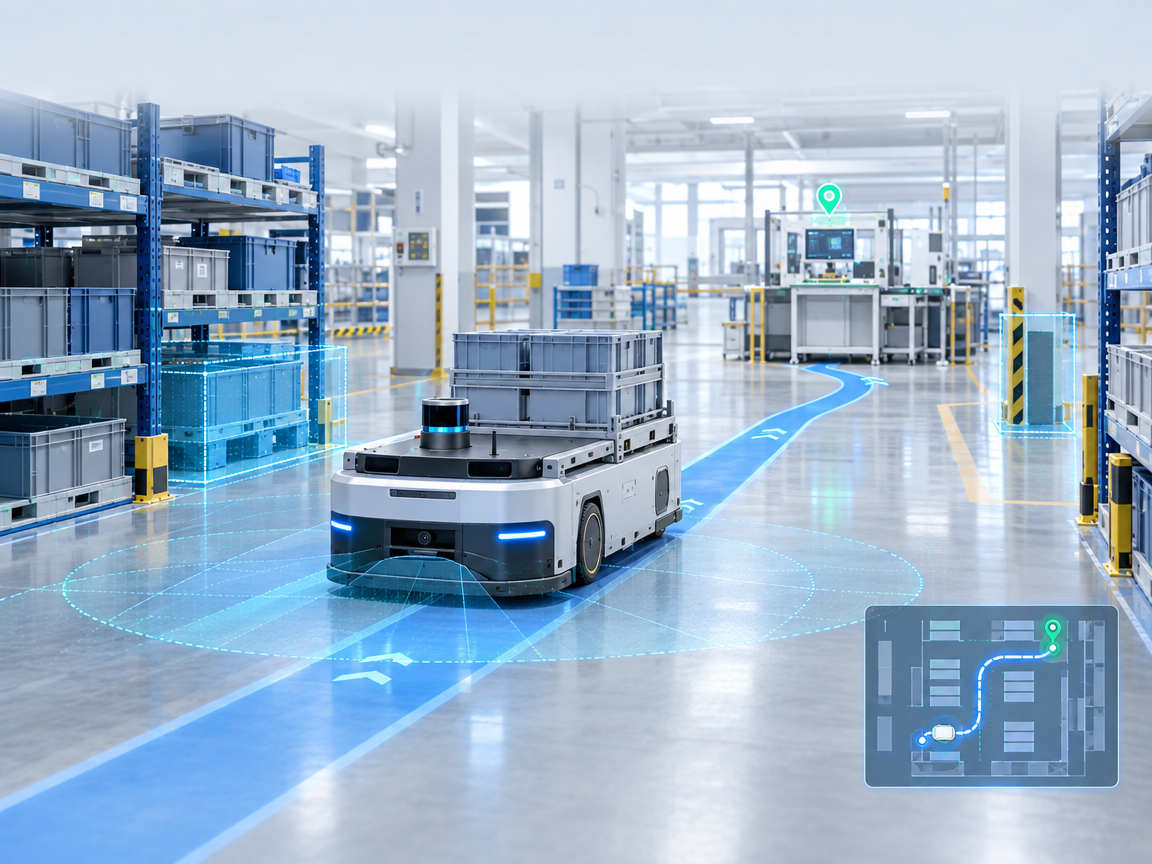
Solution Overview
Plan maps, routes, localization, and docking so AGVs can reach stations reliably in warehouses and factories. Evaluate turns, detours, and docking separately from straight-line travel.
Map management
Record operating zones, aisles, stations, and restricted areas. Track map revisions and site changes.
Route planning
Define routes, directions, and speed zones using vehicle dimensions, turning space, and site rules. Specify when a route may be recalculated.
Localization monitoring
Review vehicle coordinates, localization quality, map mismatches, route status, and docking deviation.
Station docking
Define stop positions and arrival checks for workstations, racks, and conveyors. Exchange permission signals with load-handling equipment.
Deployment Workflow
- Survey the site and confirm the mapping and navigation method.
- Set routes, restrictions, docking points, and speed zones.
- Test routes with and without loads.
- Verify relocalization and recovery after a layout change.
Aisle delivery
Check turning and docking with the actual vehicle and load dimensions.
Layout changes
Keep a versioned map and retest critical stations and routes after they move.
Implementation and Acceptance
Check floor flatness, reflective surfaces, rack changes, lighting, obstructions, and wireless coverage. Navigation accuracy, obstacle detection, and docking repeatability depend on the vehicle, sensors, and site.
This is a reference integration design. Scope, interfaces, deployment size, and performance depend on project requirements. The cover image illustrates an application and does not depict a delivered project.
Specifications
| Map Object | Channels, sites, restricted areas, direction and speed areas |
|---|---|
| Navigation Method | Laser, vision, QR code, or hybrid navigation, depending on the vehicle model |
| Information access | Vehicle coordinates, positioning status, navigational results |
| Dock Management | Site location, docking conditions, station verification |
| Change management | Map version, routing and retrometry records |
| Acceptance Criteria | Accessibility, station stability, repositioning and recovery of anomalies |
Product Features
- Map management: creation of map information for operational areas, corridors, sites and restricted areas, maintenance of map version and on-site layout change records.
- Route planning: Establish a viable route, directional limit and speed limit area in accordance with the vehicle ' s appearance, the converse space and the rules of the corridor, with clear re-planning triggers.
- Positioning monitoring: Access to the quality of position, current coordinates and navigation provided by the vehicle, showing information on location anomalies, map mismatches and station deviations.
- Site docking: Set a docking and checking process based on the needs of the site, shelf or delivery line and exchange permitted operational signals with the discharge equipment.
 Ms. Lei
 Mr. Pang