


ZJ-IR06
Model: ZJ-IR06 (programme number)
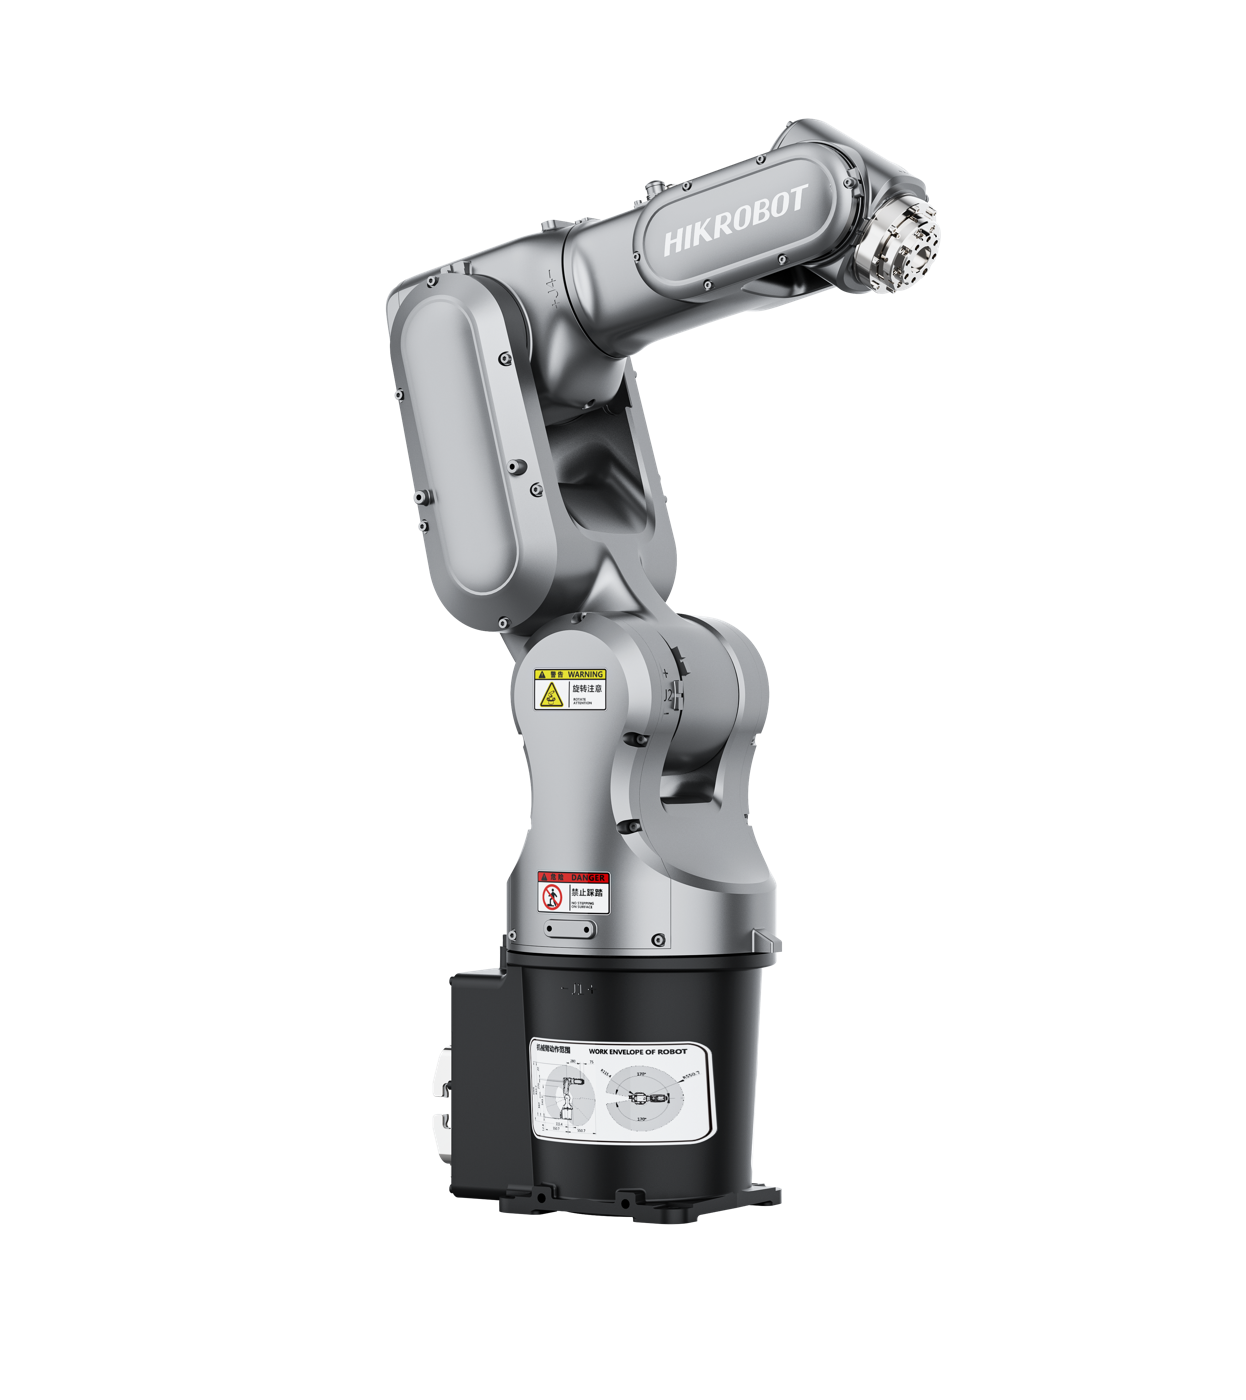
Product programme
A six-axis articulated robot configuration for machine tending, material handling, and part sorting. The reference sizing uses a 4 kg payload and 550 mm reach. The final specification depends on the selected arm and end effector.
Apply direction
Production line material handling, separation of materials from work items on the floor, and programme configuration based on field task processes, use of environment and interface needs.
Profile Description
The following are the programme reference configurations used for selected types of communication; the model is self-numbered, and parameters do not represent the measured or plant commitment value of the graphic equipment, which ultimately depends on the confirmed delivery configuration.
This page of the product diagram is selected from the Haiccon robot HAR4-550; self-numbered program does not represent the Haecon official model.
Specifications
| Program Type | ZJ-IR06 (self-programming) |
|---|---|
| Structure form | Six-axis Vertical Multi-Hystal |
| Reference Load | 4 kg (reference type) |
| Reference arm show | 550 mm (reference option) |
| End Tool | Cracket, suction etc. (selected by work) |
| Control Configuration | Control cabinets and preachers (as-needed) |
| Installation | Designed by space and equipment conditions |
| Task Type | Grab, move, top and bottom, sort. |
| System docking | Visual, PLC and line control (integrated on demand) |
| Parameter Nature | Program reference configuration, to be validated |
Product Features
- Select a clamp or a snuff by the shape of the work and load
- Plan the move around production sites and the top tectonics
- Optional visual positioning for work-related identification and capture
- Design PLC and the production line interfaces according to field control conditions
 Ms. Lei
 Mr. Pang